PERSONAL PORTFOLIO / SELECTED WORK
Binyam Abraha.
Projects & experiments.
Explore my work through the portals below.
PERSONAL PORTFOLIO / SELECTED WORK
Explore my work through the portals below.
01 / ABOUT ME
I build data systems and tools that make their results easier to investigate.
My projects explore the path from raw information to something useful: reporting that preserves its source, research tools that expose their assumptions, and interfaces that let you follow the details.
Here you can explore Relay, an order and inventory reporting system; Courtside, a basketball research application; and Episode, a robotics dataset inspection and curation tool.
Find me on GitHub ↗These projects were developed with AI assistance. The implementation and its limitations are documented with each project.
 Recorded interface / synthetic data
02 / DATA ENGINEERING
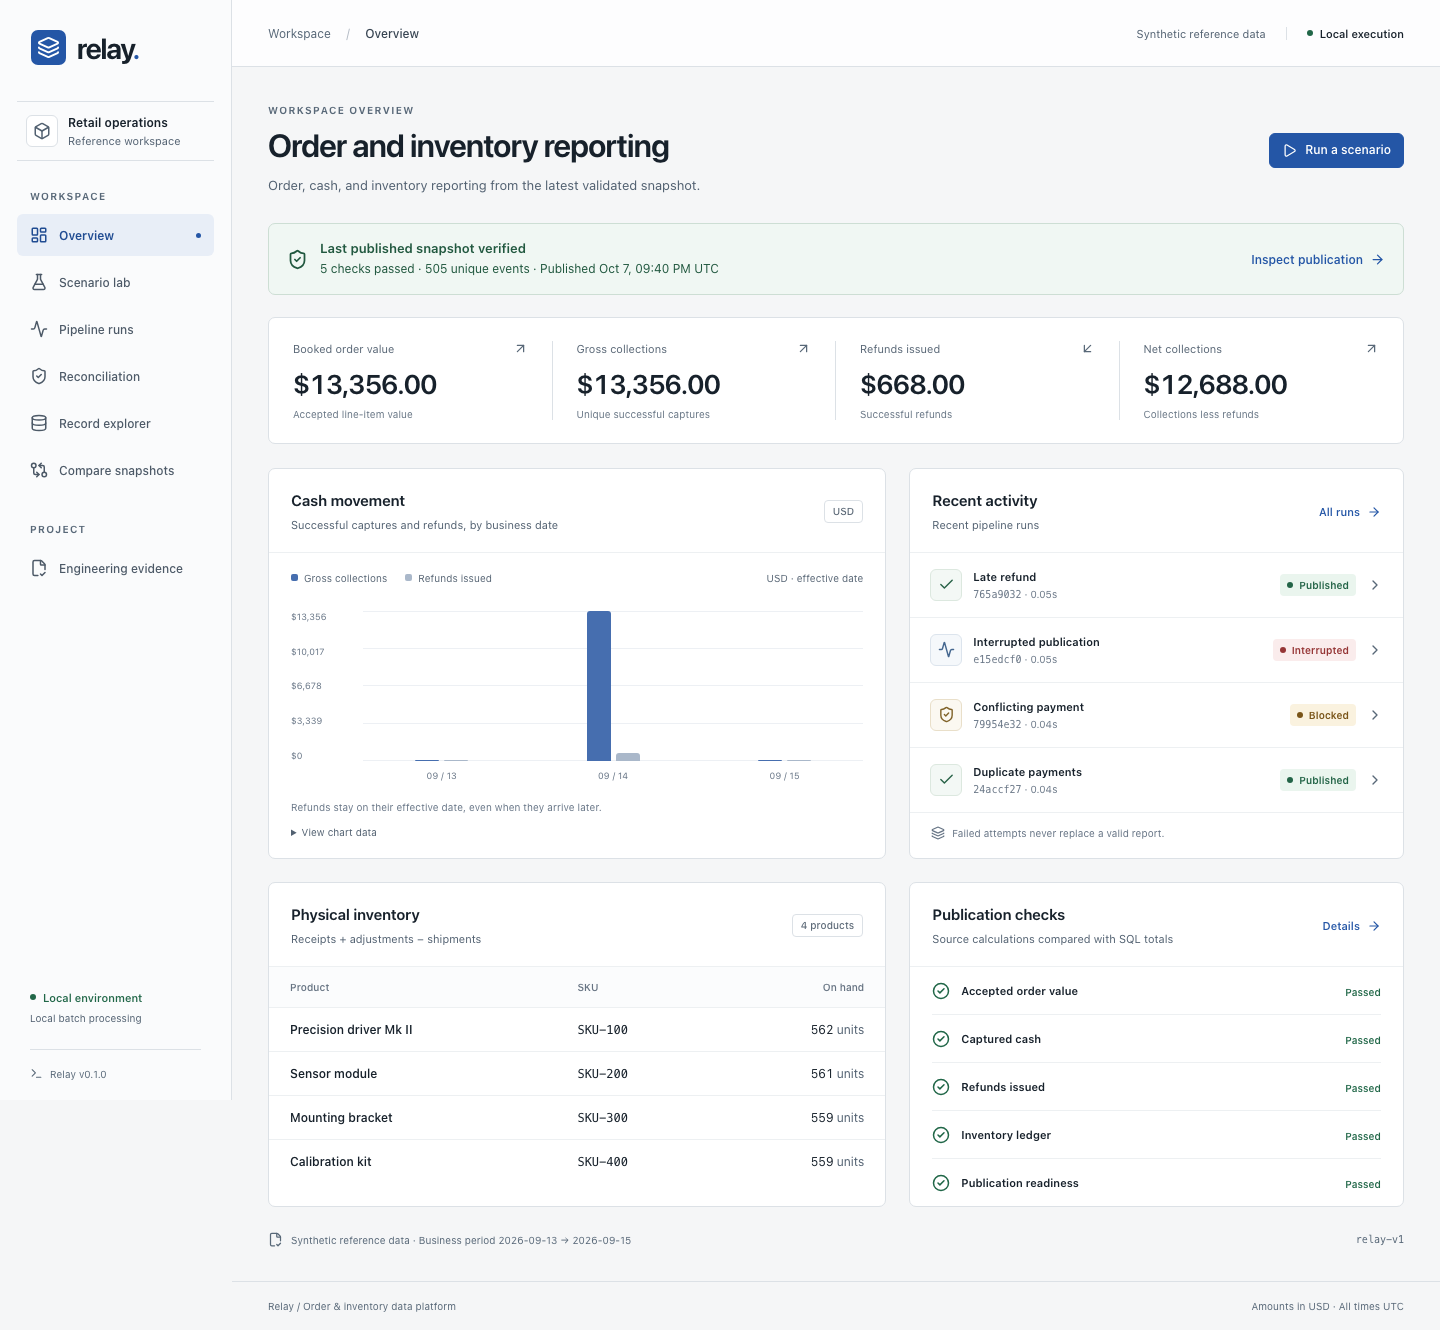
Business reporting you can trace back to the source.
Relay processes orders, payments, refunds, and inventory events. It separates repeated deliveries from conflicting records, checks the results, and publishes only complete, validated snapshots.
When processing fails, the previous valid report stays available. Run history, record lineage, and snapshot comparison make the outcome inspectable.
Explore recorded demo ↗Source & documentation ↗The demo displays saved local runs over synthetic data. It does not execute the backend. Capture time and source run are shown in the demo.
 Project artwork
03 / RESEARCH APPLICATION
A workspace for exploring basketball probabilities.
A matchup board, repeatable simulations, saved scenarios, and a paper journal bring a research workflow into one application. A separate historical Elo evaluation makes its methodology and evidence available for inspection.
The application keeps synthetic simulations, historical evaluation, and provider observations distinct, so each result has a clear context.
Demo inputs are synthetic. Live provider connections and current-season predictive accuracy have not been verified. No real wagers are placed.
Project preview. A public application link is not included in this portfolio yet.
 Recorded interface / source demonstrations
04 / ROBOTICS DATA
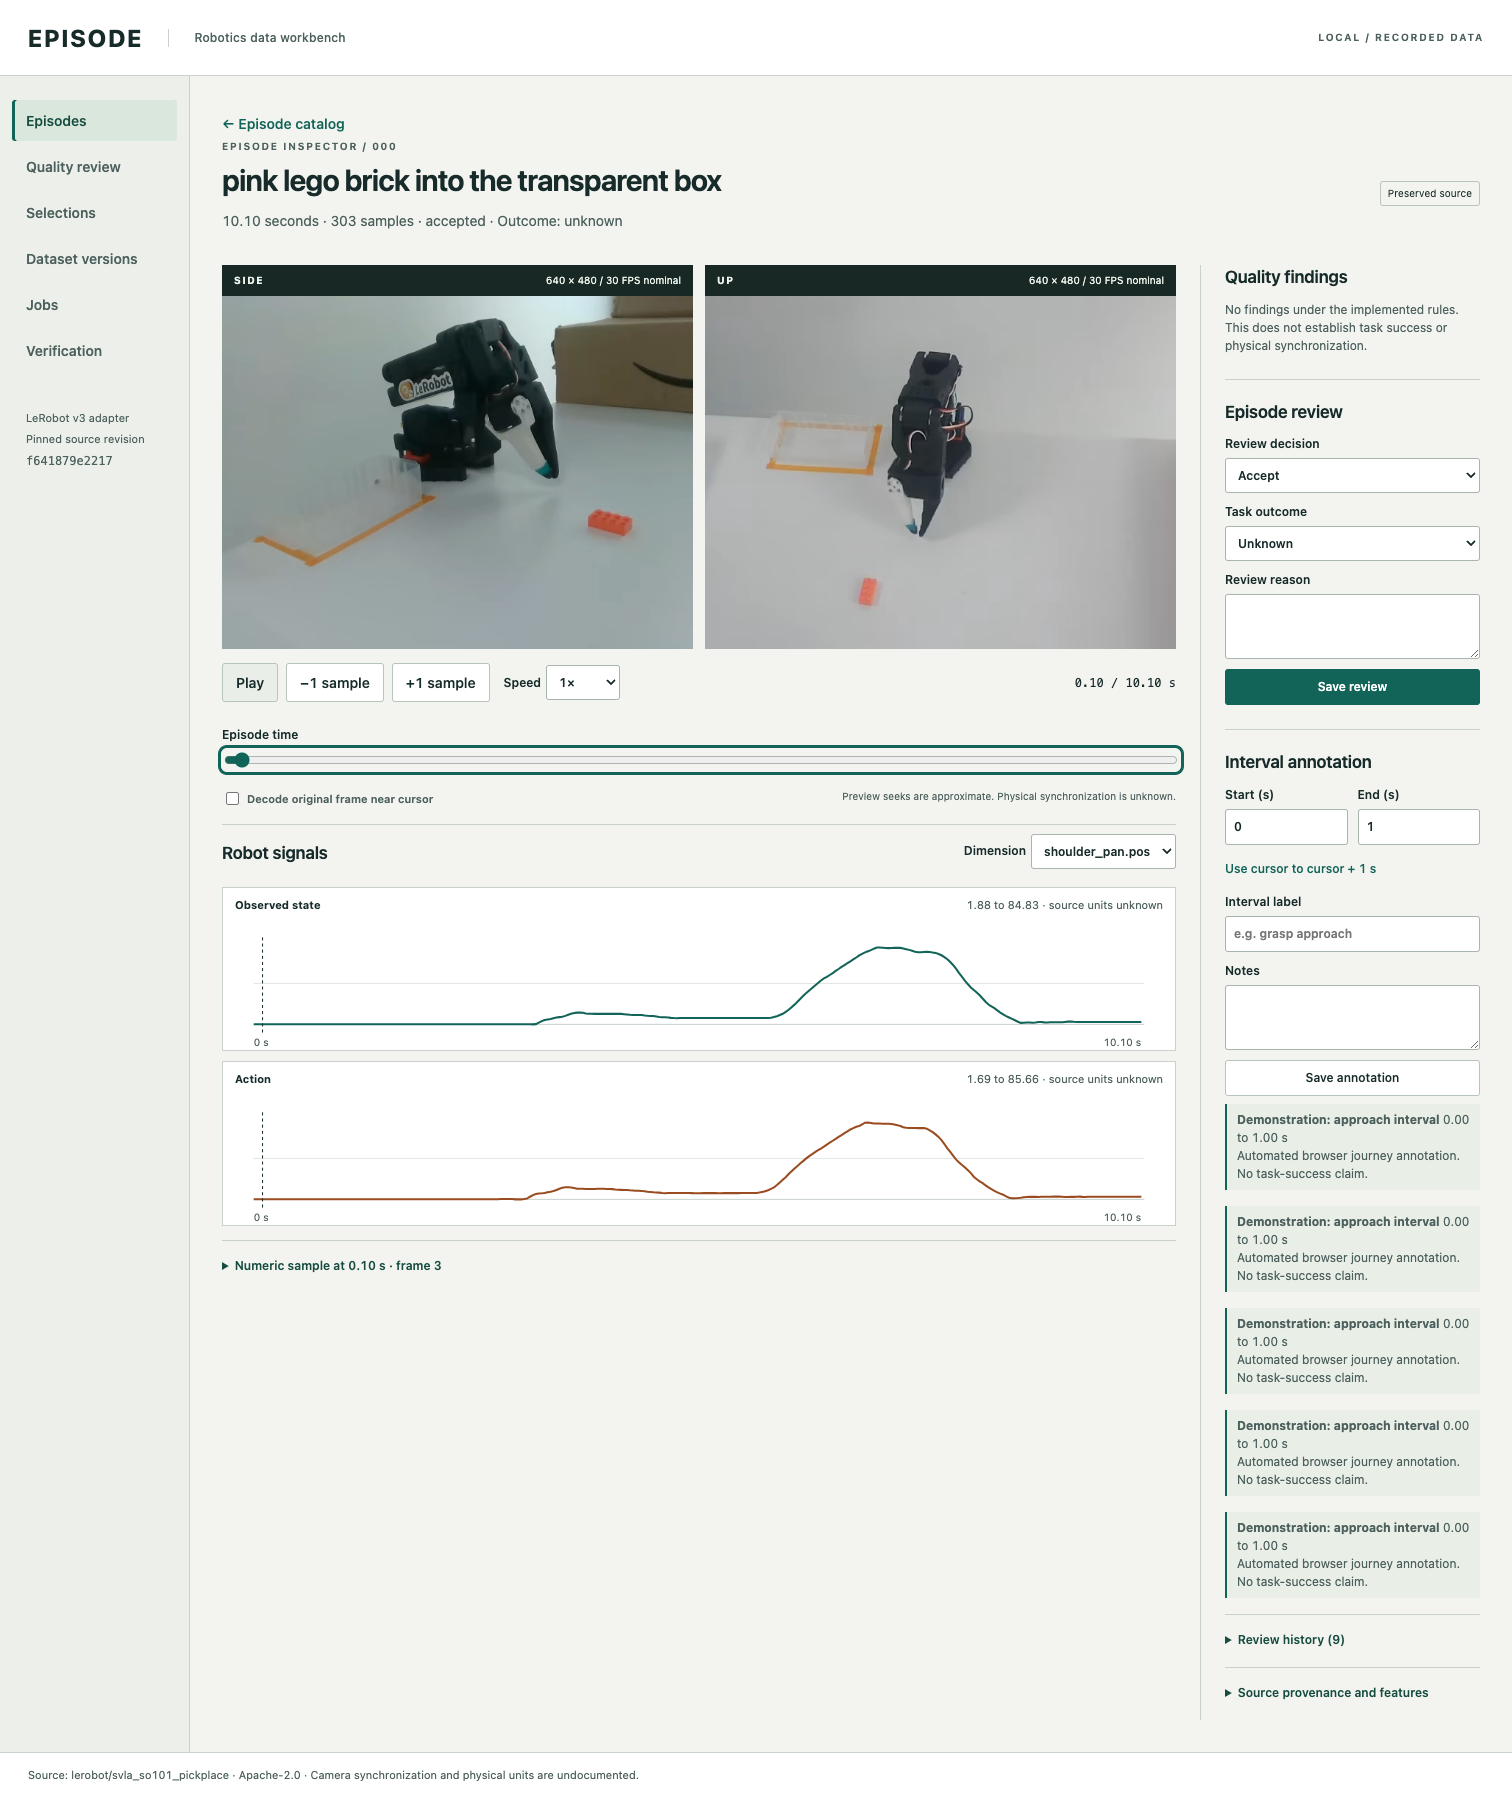
Inspect robot demonstrations and curate reproducible datasets.
Two camera views and recorded state/action signals make each demonstration inspectable. Review history, interval annotations, and saved selection criteria support dataset curation.
Optional local vision-language model suggestions include evidence and require human review. Immutable dataset versions preserve selection and analysis provenance for a standalone consumer.
Source & documentation ↗Read the technical case study ↗A local inspection and curation application. Model suggestions require review; their semantic accuracy has not been evaluated. No robot control or policy training is claimed.
Built with AI assistance. The repository documents executed checks and limitations. A hosted interactive demo is not linked here.
05 / OUTSIDE OF WORK
Sewing, Muay Thai, cooking, and time outside.